Open Core: The Robot ‘Brain’
Status: Fabricated – Being Tested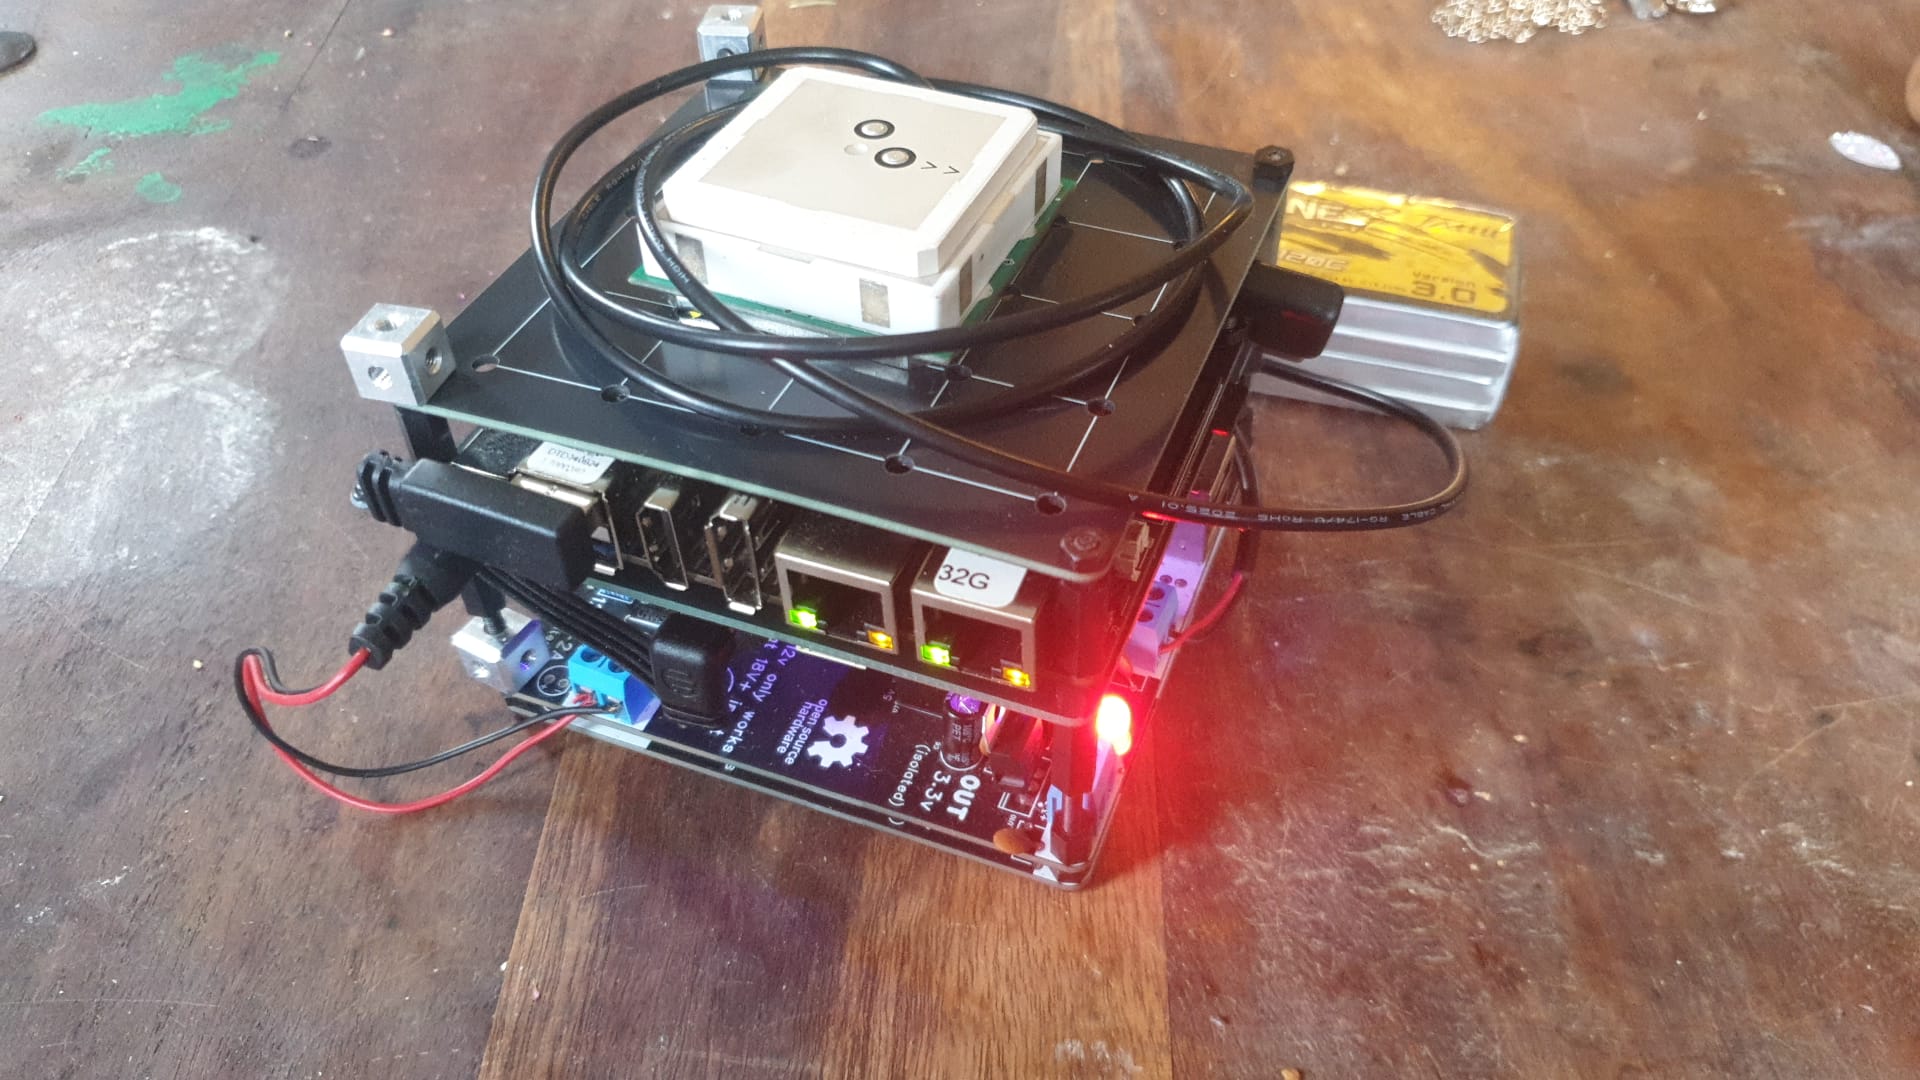
A fully open-hardware robot compute unit built around a stackable 10 cm × 10 cm module standard with two Avaota A1 Single Board Computers (SBC) connected via a single ethernet cable. Native CAN bus support enables robust field-level communication. Dual GNSS RTK receivers provide centimetre-scale positioning for navigation and task execution.
All schematics, PCB layouts, and firmware are released under open licences. The system is housed in a rugged, waterproof aluminium enclosure with M12 connectors, designed for long-term outdoor deployment.
Board A: Control & Safety
Primary controller responsible for the robot’s physical integrity and movement.
- Core Tasks: ROS 2 navigation stack, topological mapping, and EKF localization.
- Hardware: Direct serial link to the ESP32 (Lizard firmware) for deterministic real-time control.
- Priority: Executes real-time path planning and emergency stop logic.
Board B: Perception & AI
Dedicated vision processor for compute-heavy tasks.
- Core Tasks: Camera drivers, image pre-processing, and neural network inference (e.g., YOLO).
- Output: Processes raw video into lightweight detection coordinates or semantic labels.
- Priority: High-bandwidth data handling without impacting SBC A’s CPU stability.
Brain Bill of Materials
| Photo | Component & Link | Description | Qty |
|---|---|---|---|
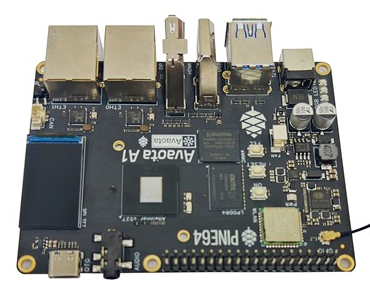 |
Yuzuki Avaota-A1 SBC | Octa-core 64-bit ARM Cortex-A55, 4 GB RAM, integrated AI accelerator. | 2 |
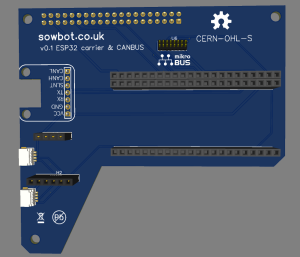 |
ESP32-S3 Microcontroller | Carrier board for ESP32 for Real-time Lizard control node and general-purpose peripheral I/O. | 1 |
 |
BNO085 IMU | Adafruit 9-DOF Absolute Orientation IMU Fusion Breakout. | 1 |
 |
CAN Bus Breakout | CAN interface breakout for deterministic, vehicle-grade communication. | 1 |
 |
SparkFun GNSS RTK (or Septentrio Mosaic) |
High-precision GNSS positioning with RTK support. | 2 |
 |
Tri band GNSS antenna | Antennas for RTK. | 2 |
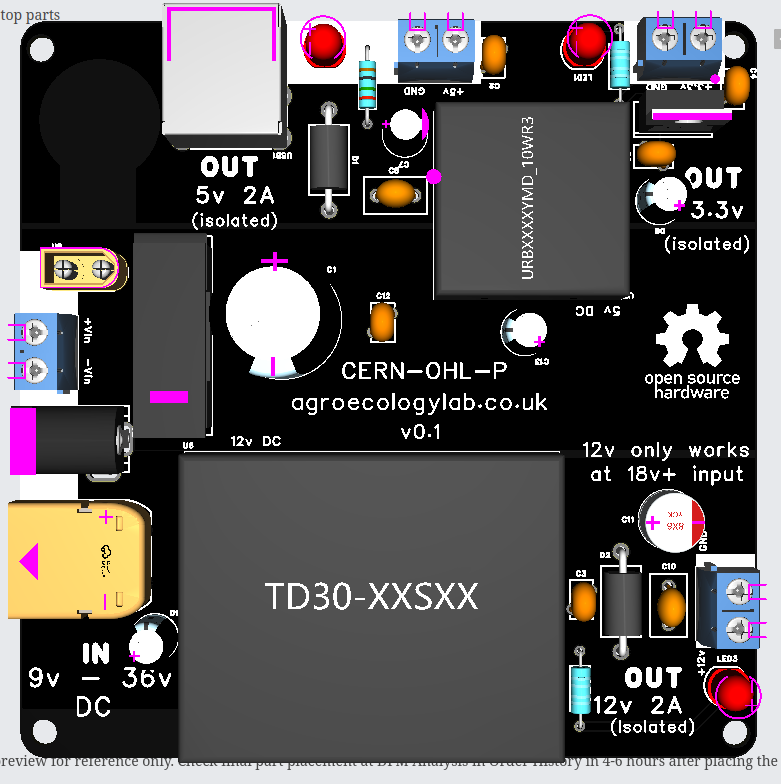 |
36V → 12V & 5V Power Isolation | Custom-fabricated power regulation board (~£30). | 1 |
 |
Simple mount plate | 10cm x 10cm mount plate with 20mm holes (~£10/5). | 1 |
 |
Waterproof Enclosure | Sealed aluminum enclosure with M22 connectors. | 1 |
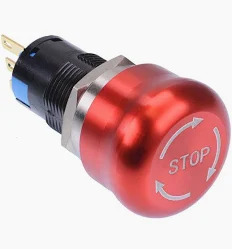 |
22mm Estop/Switch & Wiring | Includes cable, glands/90 elbow, cap, and XT60 inline fuse. | 1 set |
View full AliExpress Shopping List for Brain Components →
Sowbot: The Body
Status: BOM in review pending move to tracked platformThe Open core module above powers the Open AgBot reference platform. This integrates high-performance motors, precise control, long-lasting batteries suitable for low temp (<0C) charging, and rugged suspension into a fully modular, open-hardware agricultural robot.
Modular chassis and standardised connections enable rapid expansion and reconfiguration, providing full control over electronics, software, and mechanics for a versatile, field-ready system. Note: We are mid-pivot to a tracked platform. (For prototyping, the commercial TR500S may be suitable).
Body Bill of Materials
| Photo | Component | Description | Qty |
|---|---|---|---|
| Odrive CAN Bus Drivers | High-performance motor control. Open hardware version in dev. Migration to SimpleFOC planned. | 2 | |
| Nema 34 Odrive D6374 | Odrive motor in Nema34 format. | 2 | |
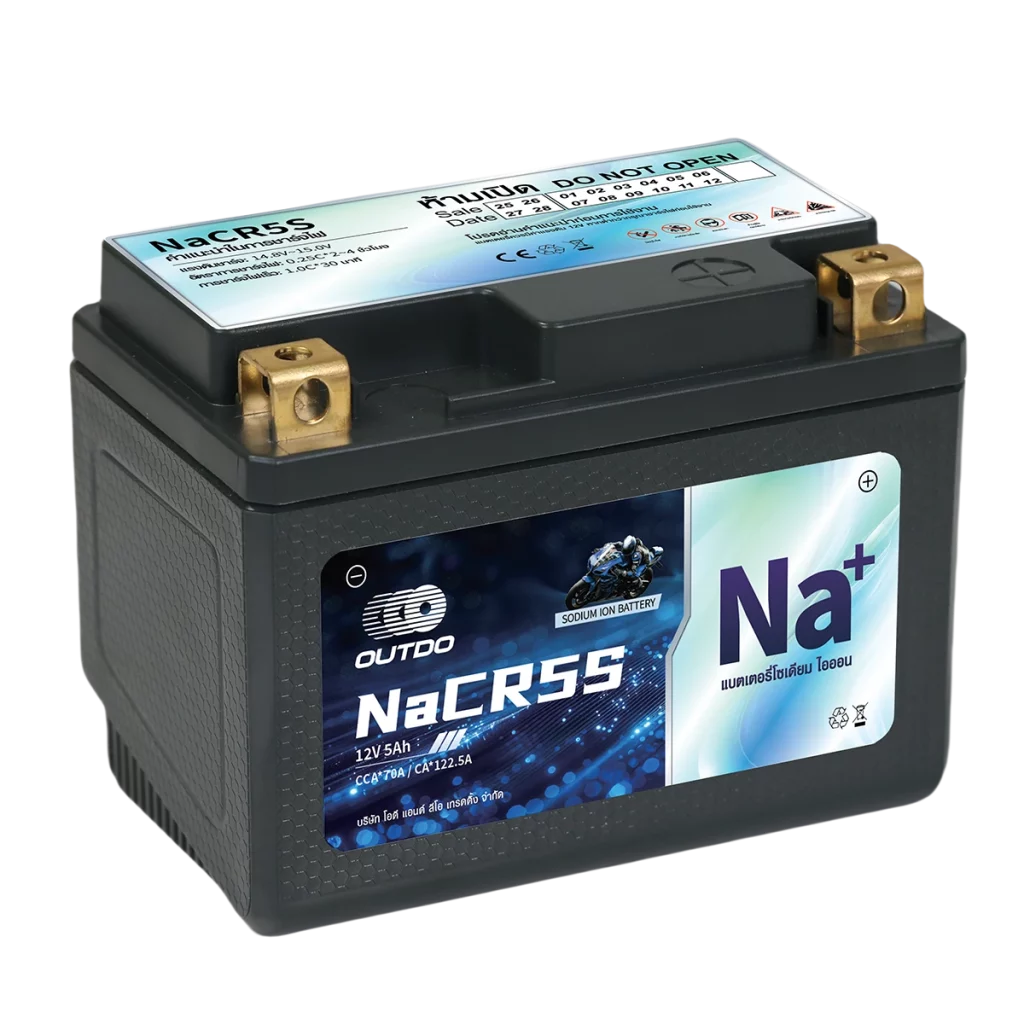 |
12V 80Ah Sodium-Ion Battery Packs | High-capacity energy modules for long-duration operation. | 6 |
| Nema 34 gearbox | Ratio TBC | 2 | |
| 5mm Aluminum Sheet & Spacers | CNC cut chassis parts. | 4 | |
| 68cm Tracks | Tracked locomotion platform (TBC). | 2 | |
 |
Chassis Connectors | Aluminium 90° crossover and modular pipe fittings for structural frames. | Many |
Sowbot Mini (Dev Platform)
Status: Needs Assembly and TestingA 1/3 scale development platform for testing and validation.
| Dev Platform Components | Description | Qty |
|---|---|---|
| Driver, Gearbox & Motors | Same as full-size platform above. | 1 set |
| Tracks | Lynx tracks (or cheaper alternatives). | 2 |
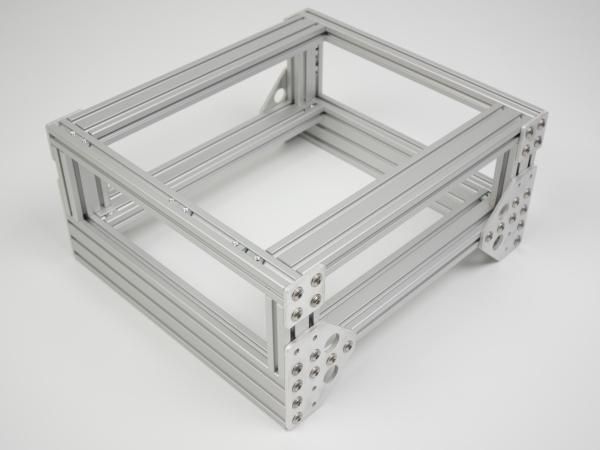
| Chassis Structure & Connections | 1515 extrusion and corner brackets. | Many |
Sowbot Pico (Dev Platform)
Status: Physical platform tested. Requires Lizard firmware work.Under review/testing in light of move to tracked chassis. Track issue here.
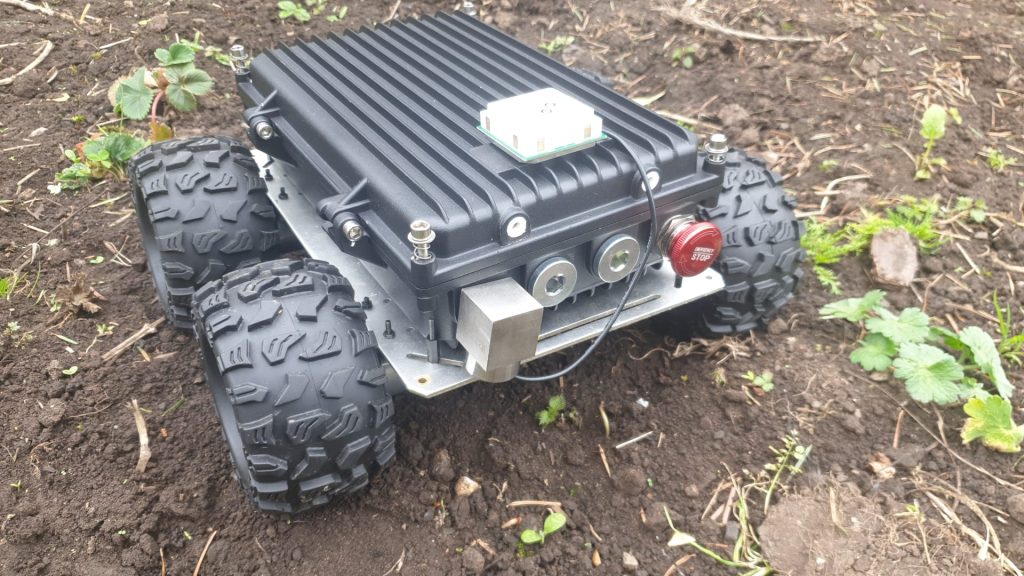
| Component | Description | Qty |
|---|---|---|
| 12V 37RPM DC Motor | High-torque speed reduction gearbox with encoders. (~$12) | 2 |
| 10kg Chassis | Small form-factor chassis. Undergoing testing. | 1 |
| Zio 4-Channel DC Motor Controller | Dual H-bridge controller, I²C Qwiic-compatible. ($14) | 1 |
| 3S Lipo & Charger | DC ~11.4V, 6000mAh battery + USB Charger. (~$30 total) | 1 set |
| Wiring & Connectors | XT60 to screw terminal, 22 AWG PH 2.0 cables. | 1 set |